Building at the edge of AI and the physical world.
Hi, I'm Rima Rebei. Robotics Ph.D. candidate at Harvard.

Hi, I'm Rima Rebei. Robotics Ph.D. candidate at Harvard.
In the Harvard BioRobotics Laboratory (advisor: Prof. Robert D. Howe), I develop markerless 3D hand-pose estimation for biomechanics: recovering articulated joint kinematics from consumer RGB and depth cameras instead of marker-based motion capture.
My work combines learned keypoint detection with anatomical hand models to estimate joint angles and range of motion, and validates those vision-based measurements against clinical ground truth.
The goal is to make healthcare more accessible: turning an everyday phone into a telehealth tool so patients can track joint health from home instead of traveling for every assessment. I test the system in the clinic with people living with rheumatoid arthritis, comparing what the camera measures with how clinicians evaluate their hands.
A mobile STEM lab built on culture, creativity, and confidence.
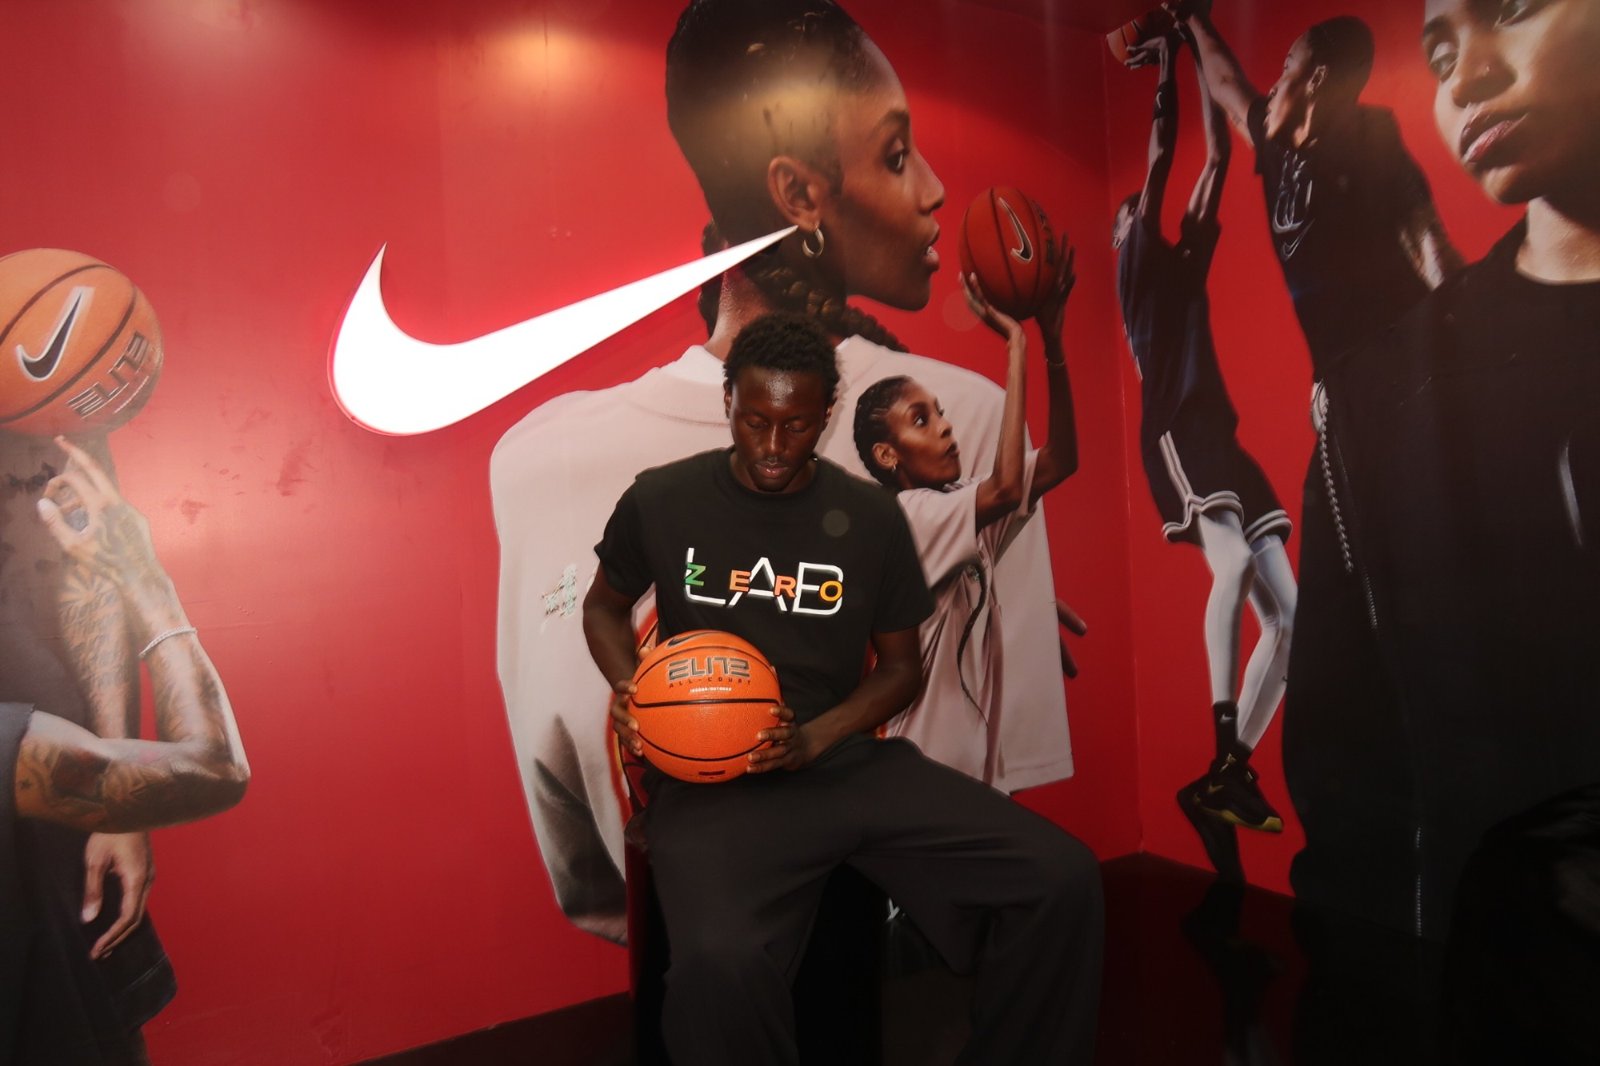
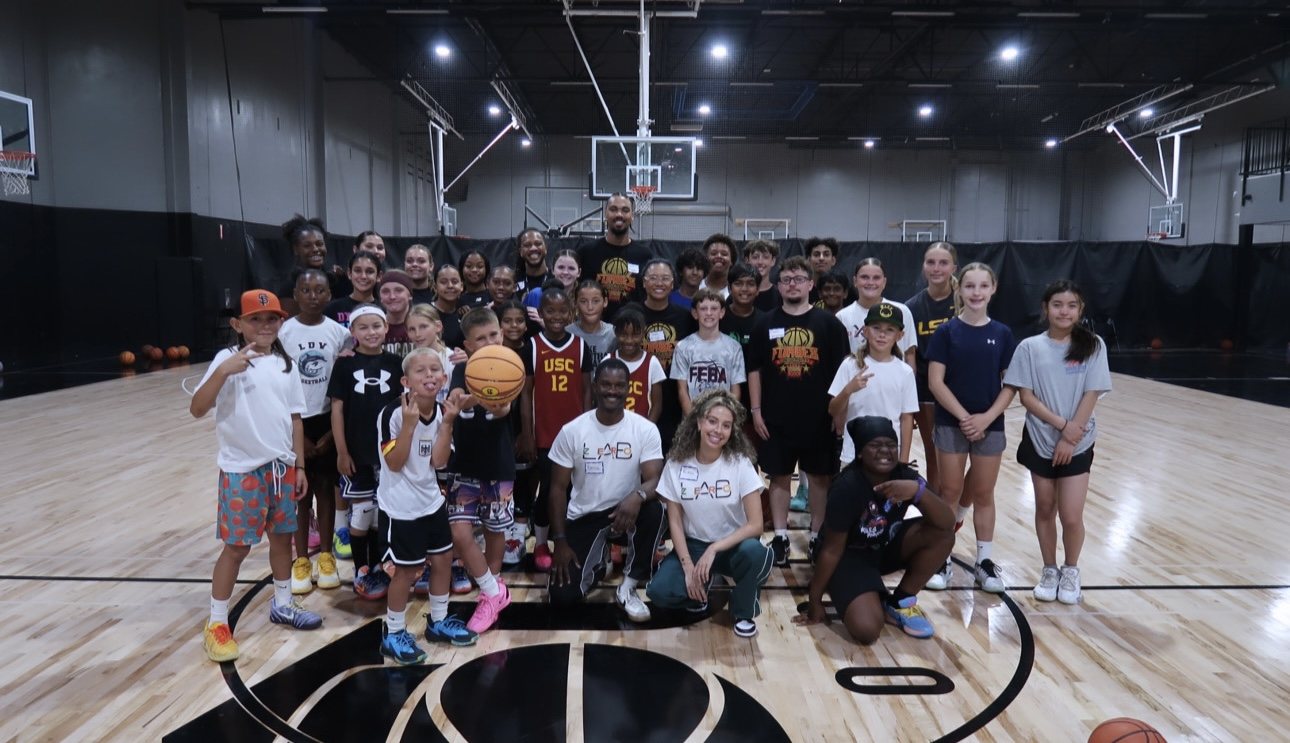
I co-founded Lab Zero to bring hands-on robotics, AI and innovation programs to young people around the world. We meet students where they are and connect engineering to what they already love, from sports to music.
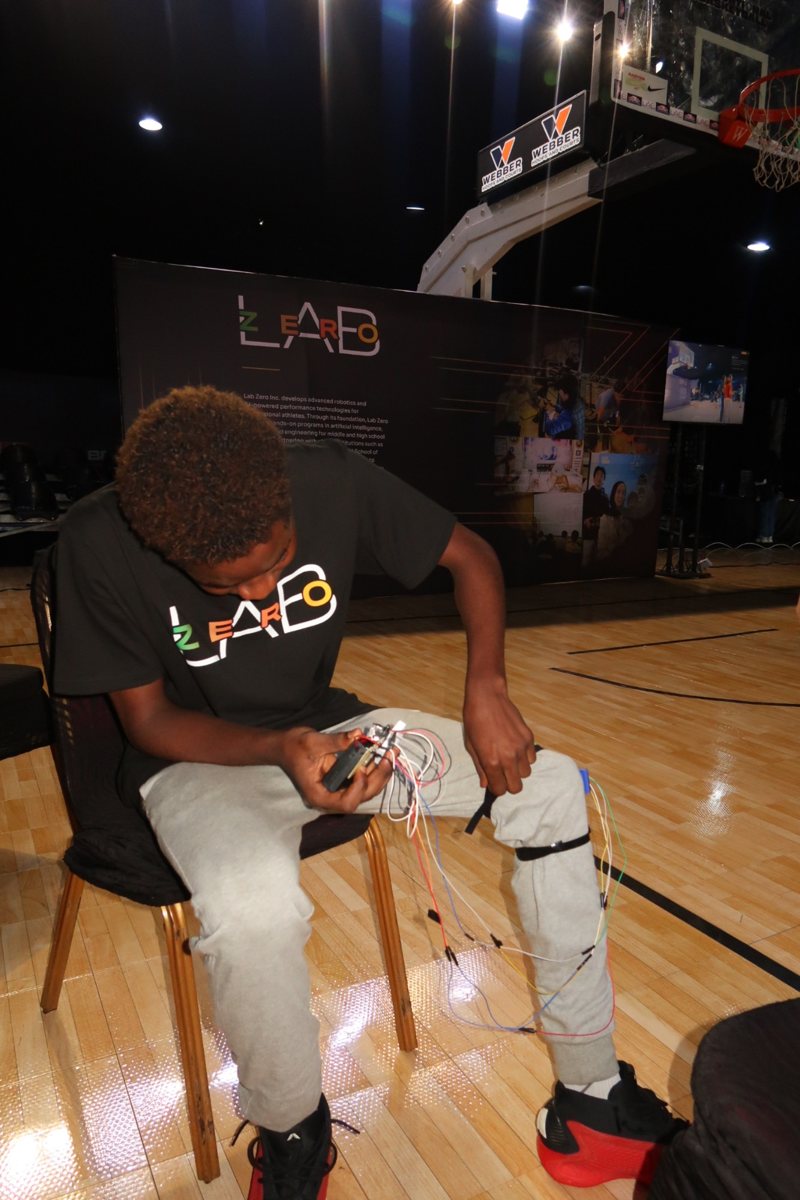
One of Lab Zero's initiatives: a sports and AI camp where students analyze their own movement with computer vision, then build sensors and wearables for their sport, from a knee-angle tracker to sport-specific projects.
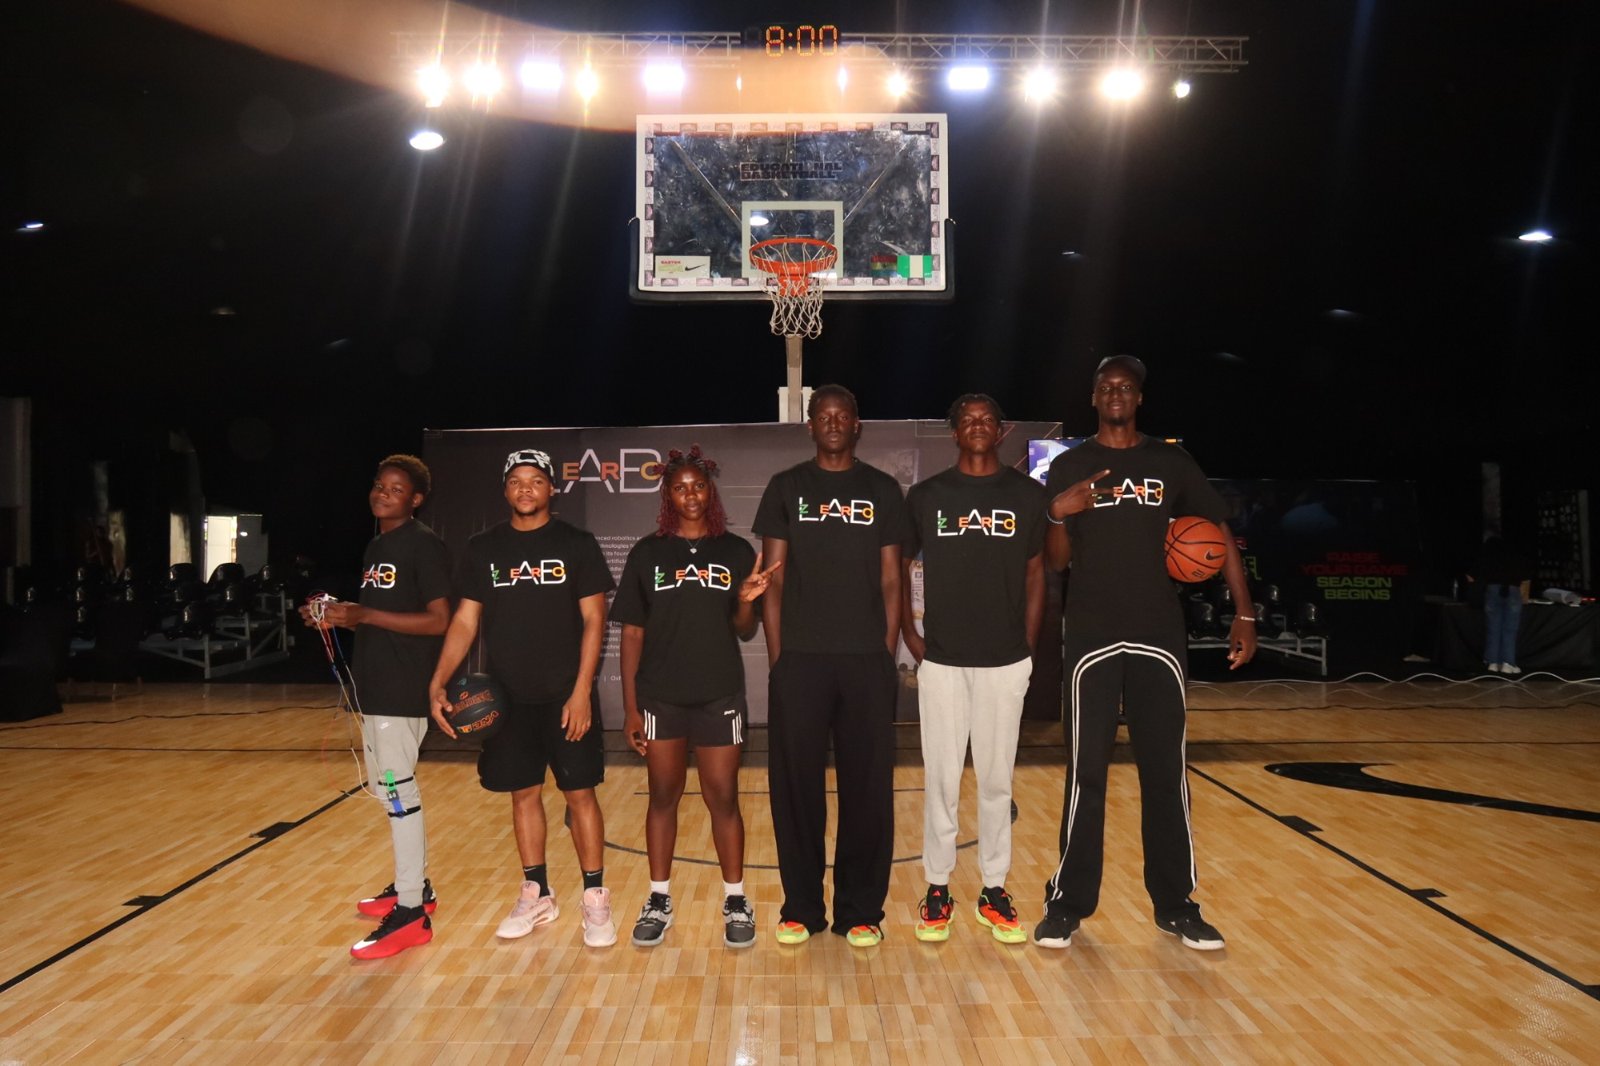
Wearables, swarms, clinical NLP and LLM tools: perception and control across robotics and AI.
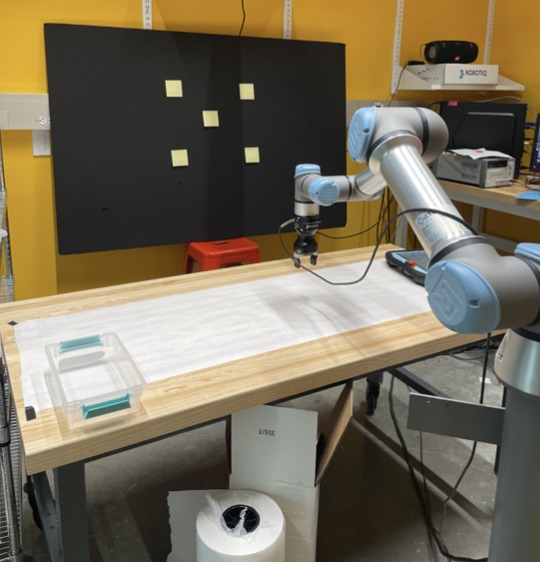
A low-cost wearable that lets people with Duchenne muscular dystrophy steer a UR5e arm and gripper using only head motion (optical flow) and blinks (EMG).
read_more →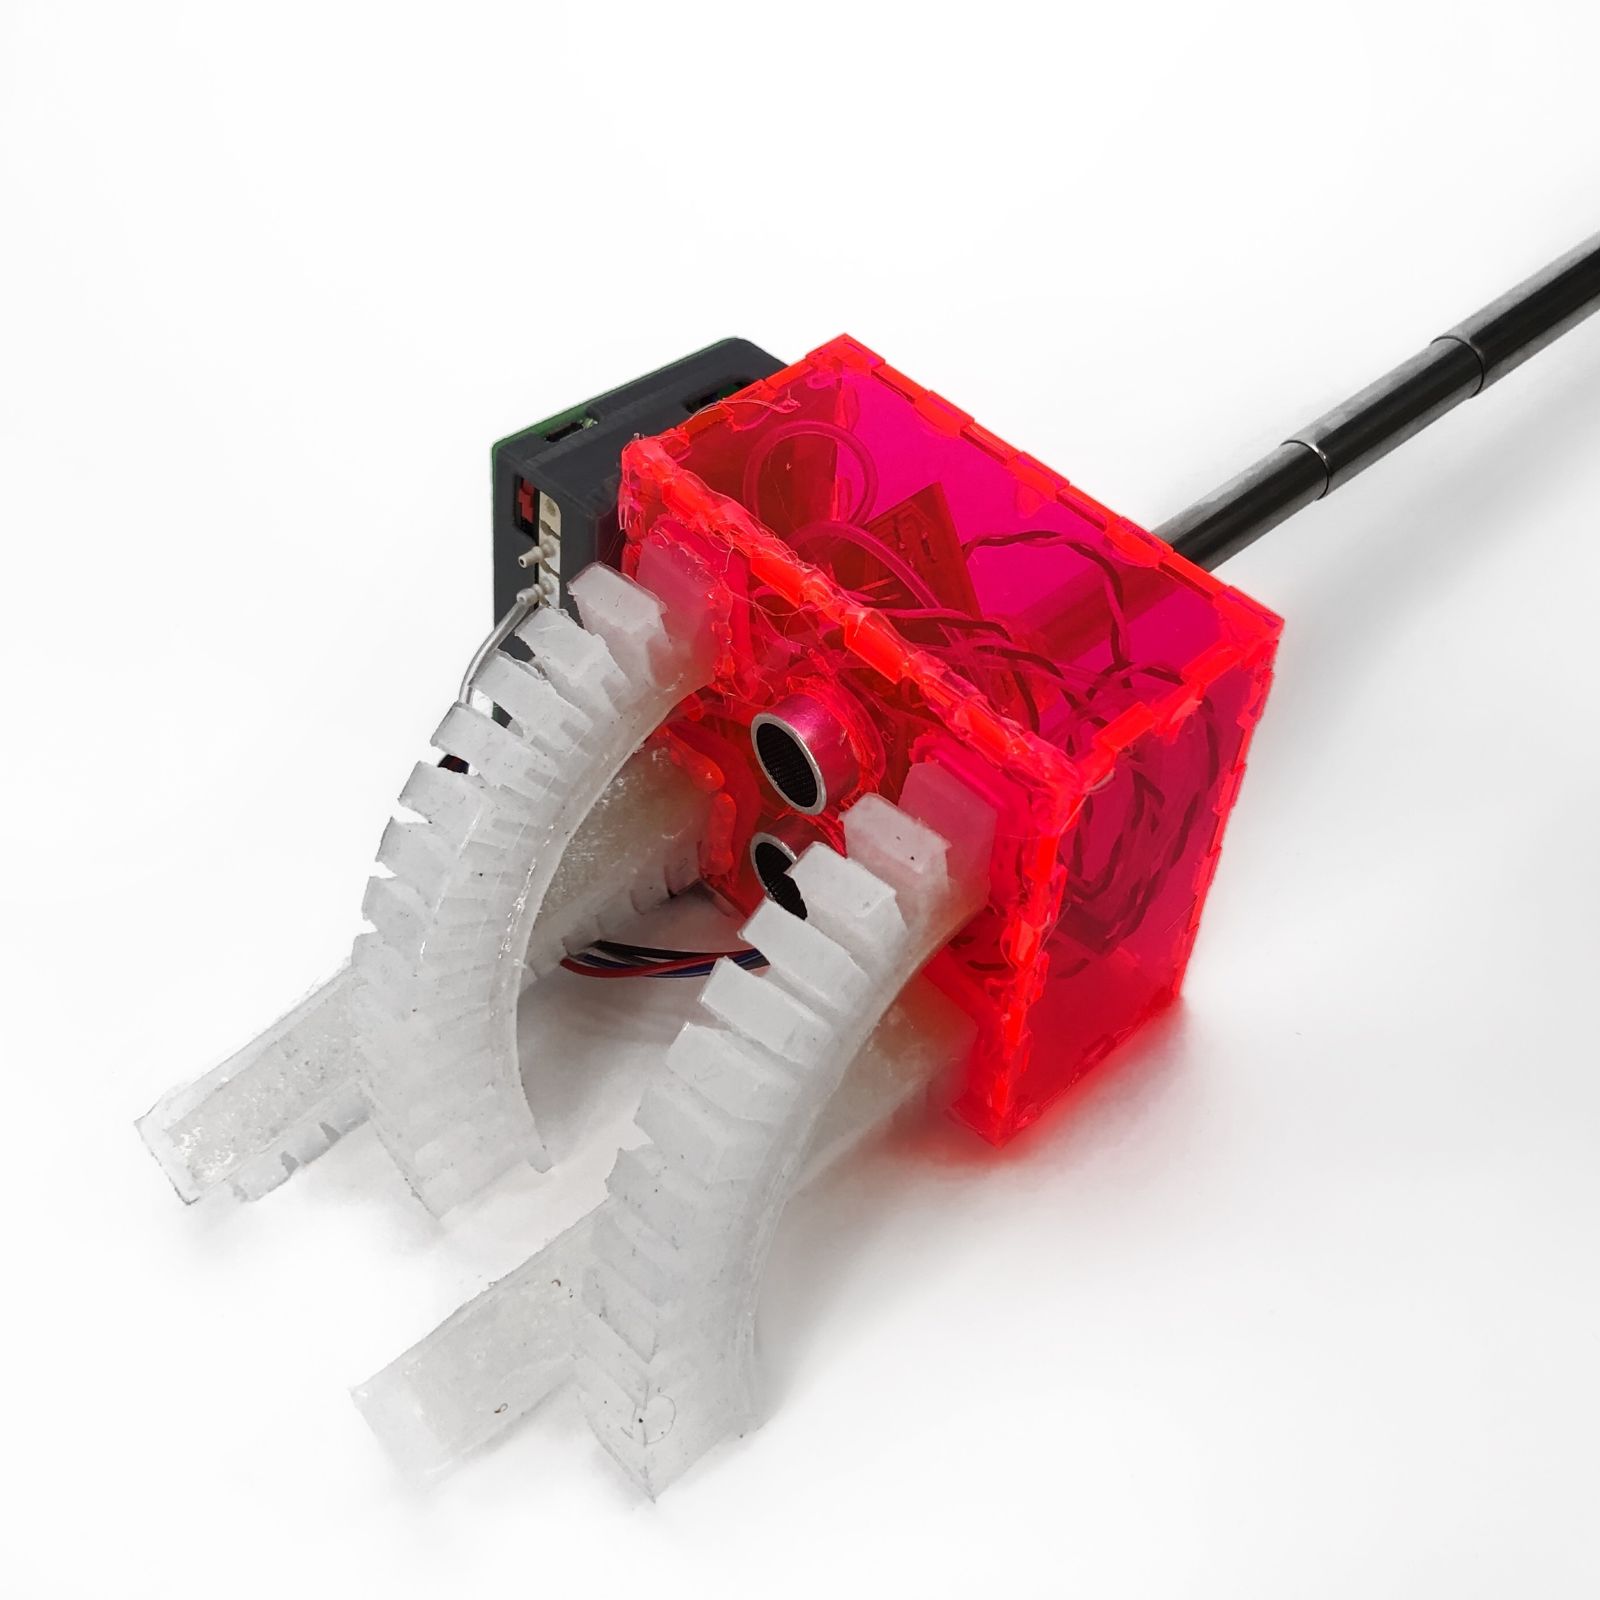
A soft robotic gripper with ultrasonic sensing and custom electronics that grasps objects autonomously, built for mobility assistance.
read_more →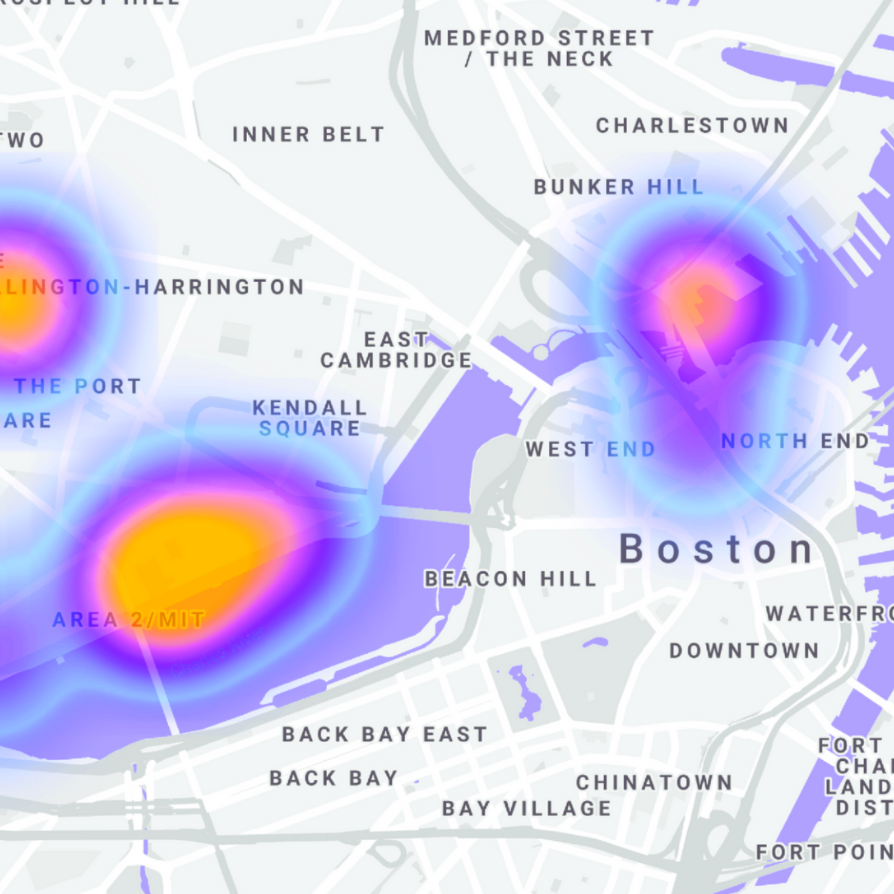
A fleet of autonomous drones that maps air pollution at 15-meter resolution in real time. Featured in MIT News.
read_more →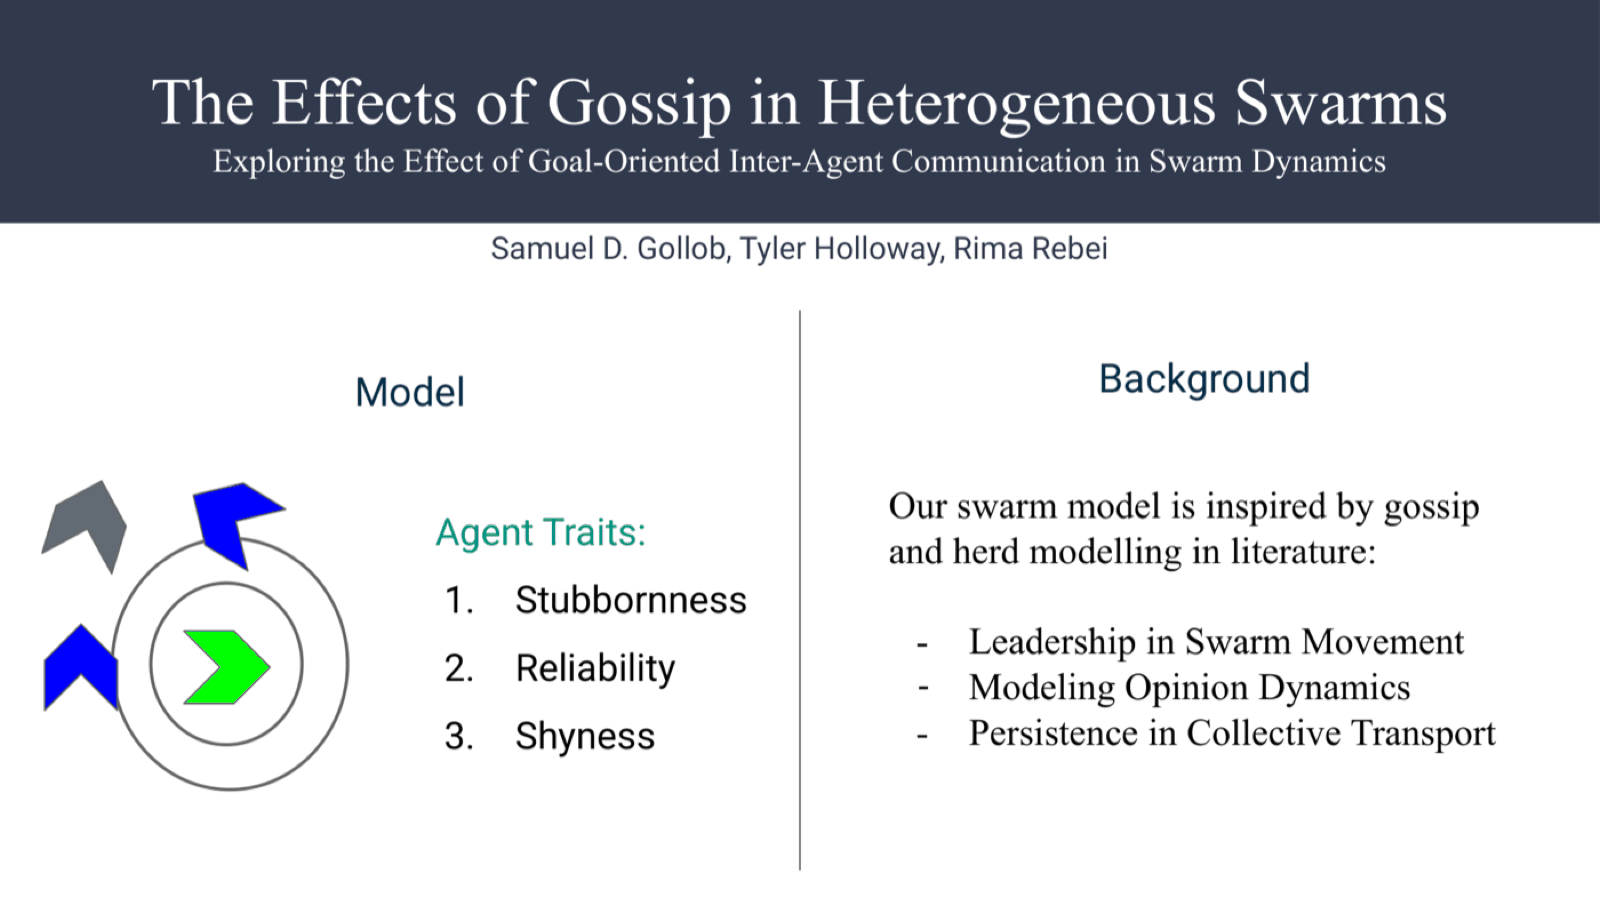
An agent-based model of how information spreads through a swarm whose members differ in stubbornness, reliability and shyness.
read_more →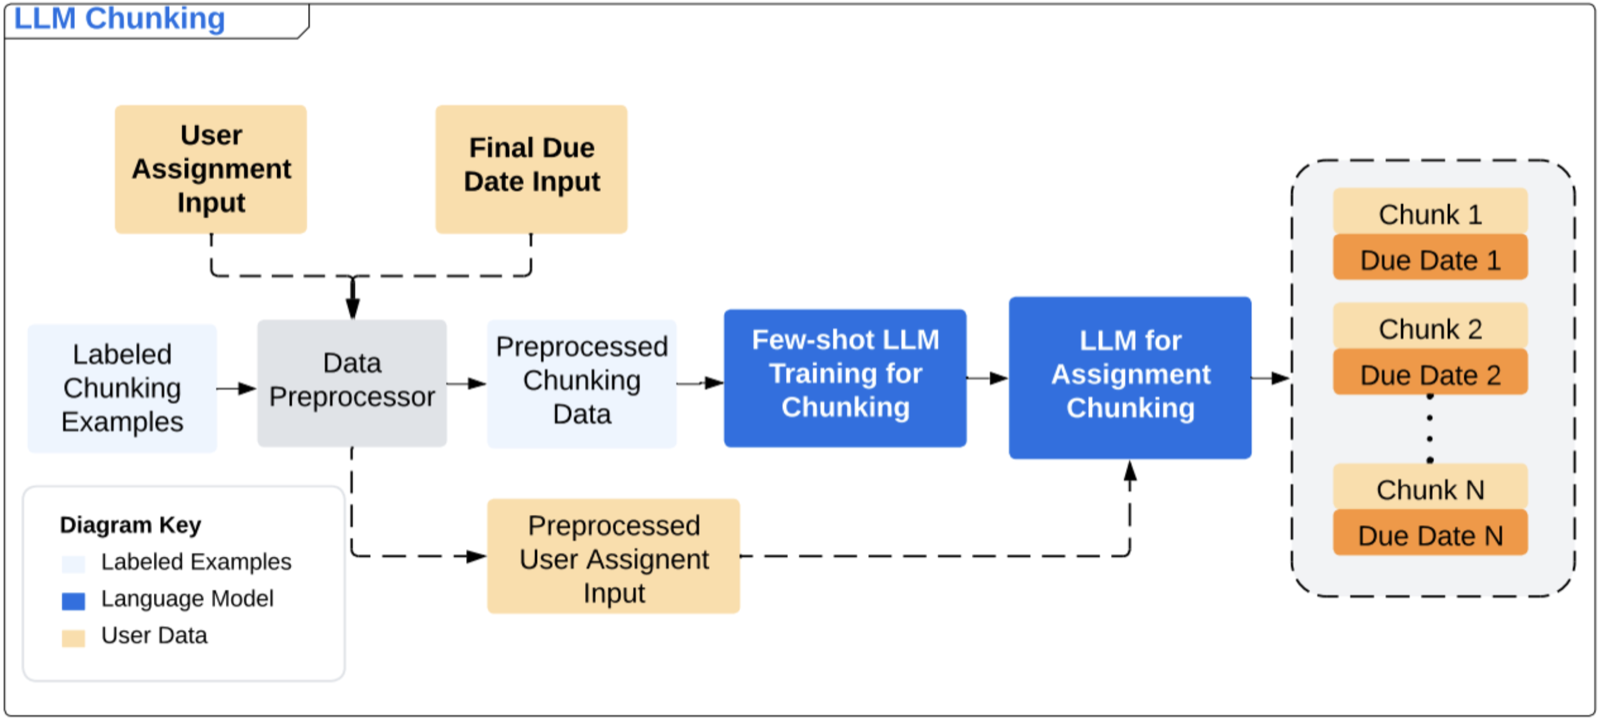
An LLM planning tool that breaks overwhelming tasks into calendar-ready steps, shaped by user interviews and a week-long field study.
read_more →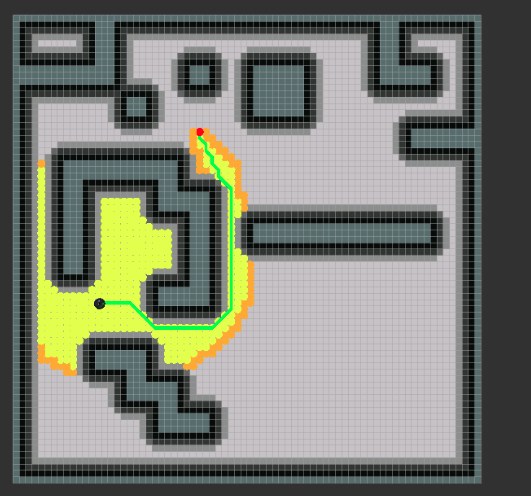
I mentored a student comparing A*, Dijkstra's and Greedy Best-First Search in ROS/Gazebo. A* cut search time about 70% compared with Dijkstra's.
read_more →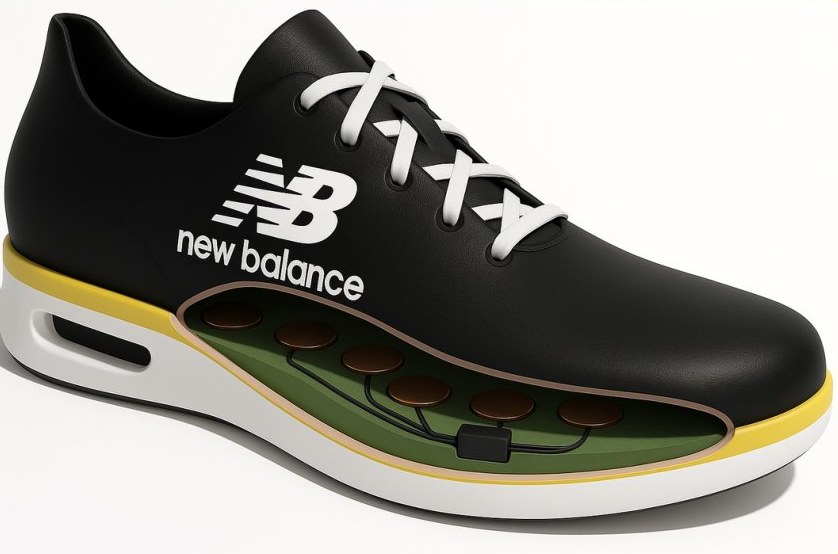
I mentored student teams building ElectroStep, a shoe with built-in microcurrent muscle recovery, and Caelis, a shoe with non-Newtonian fluid pouches for all-day comfort.
read_more →I advised Katie Le (S.B. '26) on a device that measures grip force in real time and adapts its resistance to each patient's daily strength.
read_more →Where I think the next big companies at the intersection of AI and the physical world will come from.
Foundation models leaving the screen: robots and embodied agents that perceive, plan and act in messy real-world environments.
Markerless motion capture and pose estimation turning any camera into a clinical-grade tool for rehab, sports and aging.
The data engines behind physical AI: human-motion capture, teleoperation, simulation and synthetic data that teach robots to act.
As AI reshapes work, what we teach has to change too: hands-on building, AI literacy and creative problem-solving for every student.
Advances in AI & robotics can deepen inequity or help close it. I want to build the kind that closes it.
I'm a Robotics Ph.D. candidate at Harvard SEAS, where I use computer vision to study how people move. Before that I earned my master's in Computer Science at Harvard and studied Mechanical Engineering and Computer Science at MIT.
My work spans the robotics stack: soft grippers, autonomous drones, wearables, pose estimation and LLM tools. It keeps coming back to one question: how can technology understand the human body well enough to actually help people?
At Harvard Business School, I'm a Doctoral Teaching Fellow for Designing Technology Ventures (Fall 2025 and Fall 2026). The class focuses on how founders turn an idea into a technology product: finding real customer needs, prototyping, testing with users and building toward product-market fit.
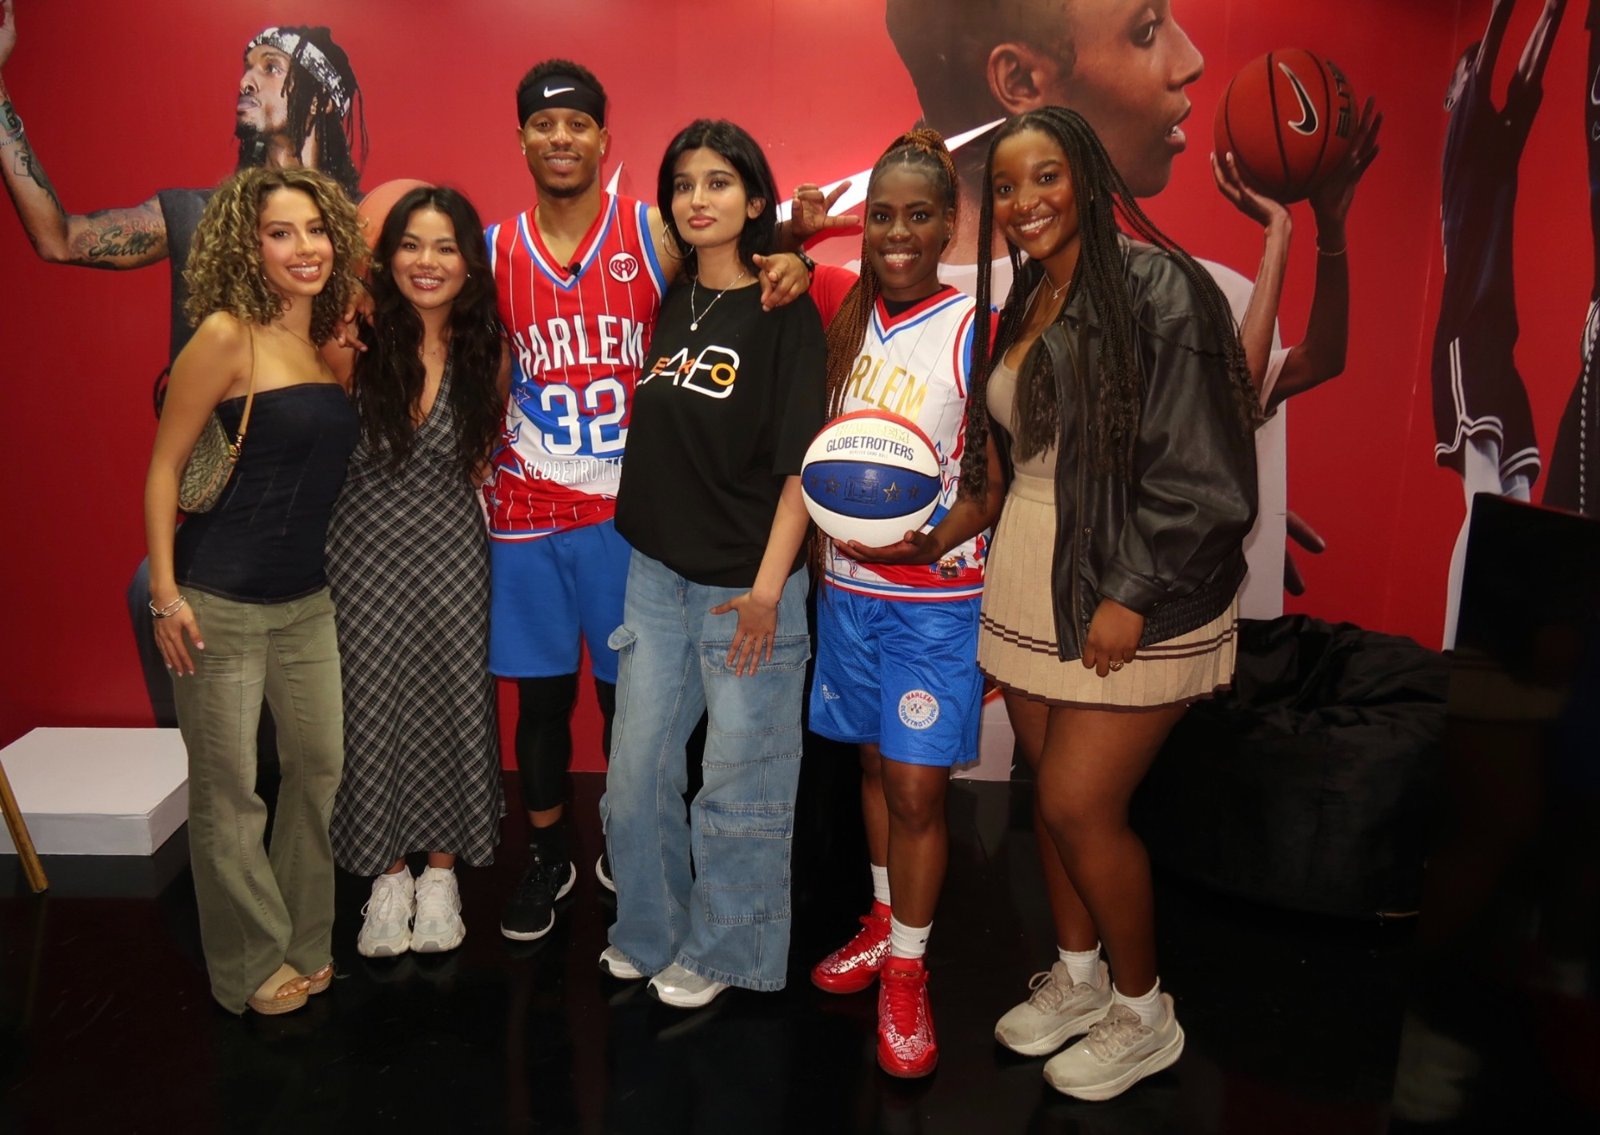
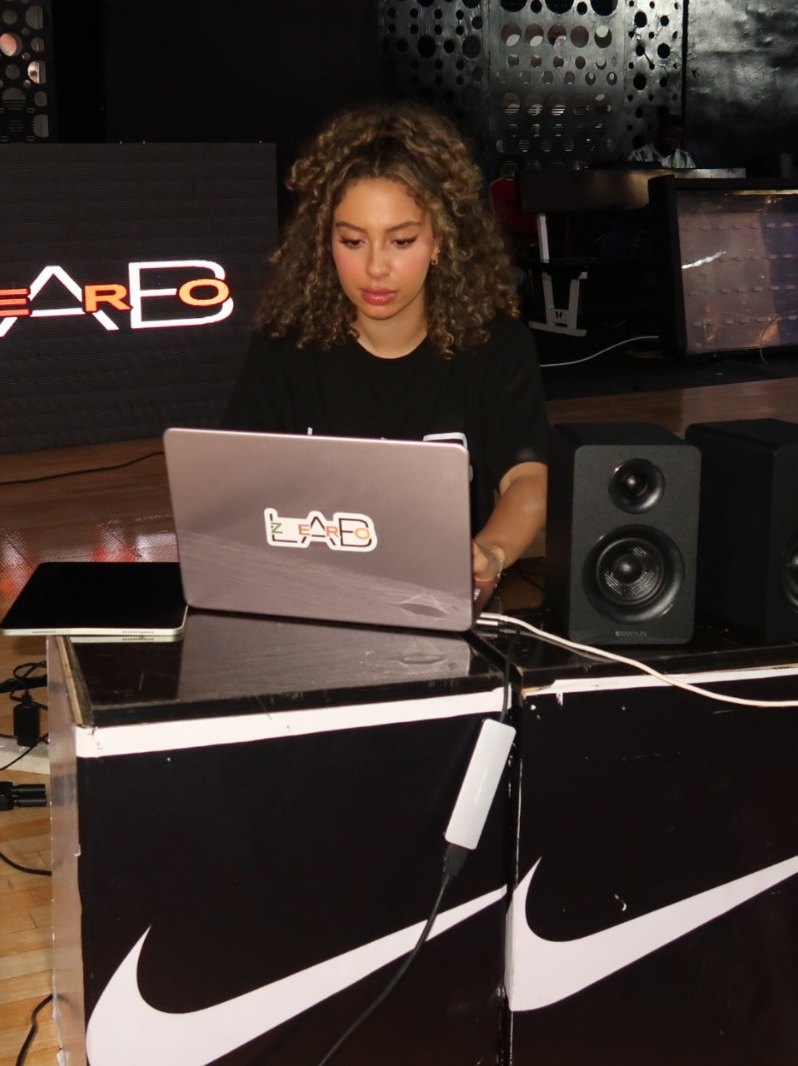
Outside the lab I co-run Lab Zero, which has run AI and robotics programs in 20+ cities across 10+ countries, with partners like Nike and the Harlem Globetrotters. I mentor engineering design teams and student researchers, travel every chance I get, and play in a jazz band.
I'm always happy to talk about computer vision, robotics, STEM education, venture investing or partnering with Lab Zero.